01 / ROBOTICS
A robot cannot wait for the cloud
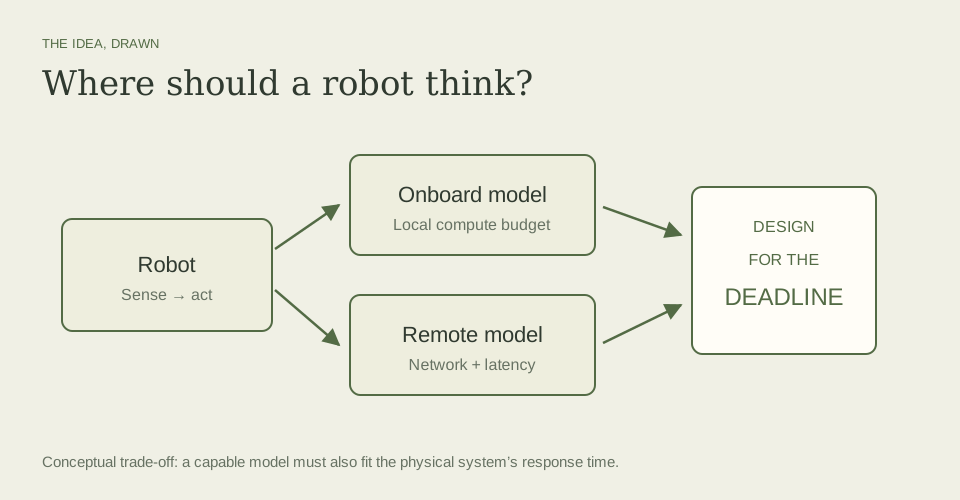 Conceptual trade-off: a capable model must also fit the physical system’s response time.
SemiAnalysis examines onboard versus datacenter inference. Larger remote models offer capability, but latency, network variability, and per-robot hardware costs determine what can actually work in the physical world.
Read the source ↗ newsletter.semianalysis.com02 / RESEARCH
One policy, several ways over an obstacle
RoboPapers covers Light-Loco-Parkour, a humanoid-control approach that selects walking, climbing, or vaulting using onboard sensing. The research direction: learn skill transitions instead of hand-coding a separate switch for every obstacle.
Read the source ↗ robopapers.substack.com03 / BUSINESS IDEA
Hardware needs a manufacturing layer
Half Baked proposes turning product descriptions into editable designs, parts lists, and factory-ready specifications. Its strongest point is the supplier network: a convincing render alone does not make a product manufacturable.
Read the source ↗ read.gethalfbaked.com04 / GOVERNANCE
Independent evaluation needs real access
AINews covers AEF-1, a proposed baseline for outside AI evaluations, including access, conflicts, and transparency. The useful question is whether evaluators can inspect enough of the development process to challenge a lab’s claims.
Read the source ↗ latent.space